Building Smarter Robots and Reinventing Multi-Material 3D Printing
John Whitehead is a mechatronics engineer specializing in robotics and advanced manufacturing. His work includes developing new 3D-printing technologies during his PhD, designing innovative soft robotic actuators, and building industrial automation systems at Berkshire Grey.
About JohnInverted Laser Sintering
Traditional laser sintering is largely limited to a single material and builds parts inside a deep bed of unfused powder. The process requires large amounts of material and hides the print until it is finished, potentially delaying failure detection. Inverted laser sintering addresses these limitations by replacing the powder bed with a single recoated material layer on glass. A laser directed upward through the glass selectively fuses regions of that layer onto the in-progress print. Without a surrounding powder bed, the material can be changed throughout the printing process, enabling multi-material parts made from different powders.
Learn more about the process →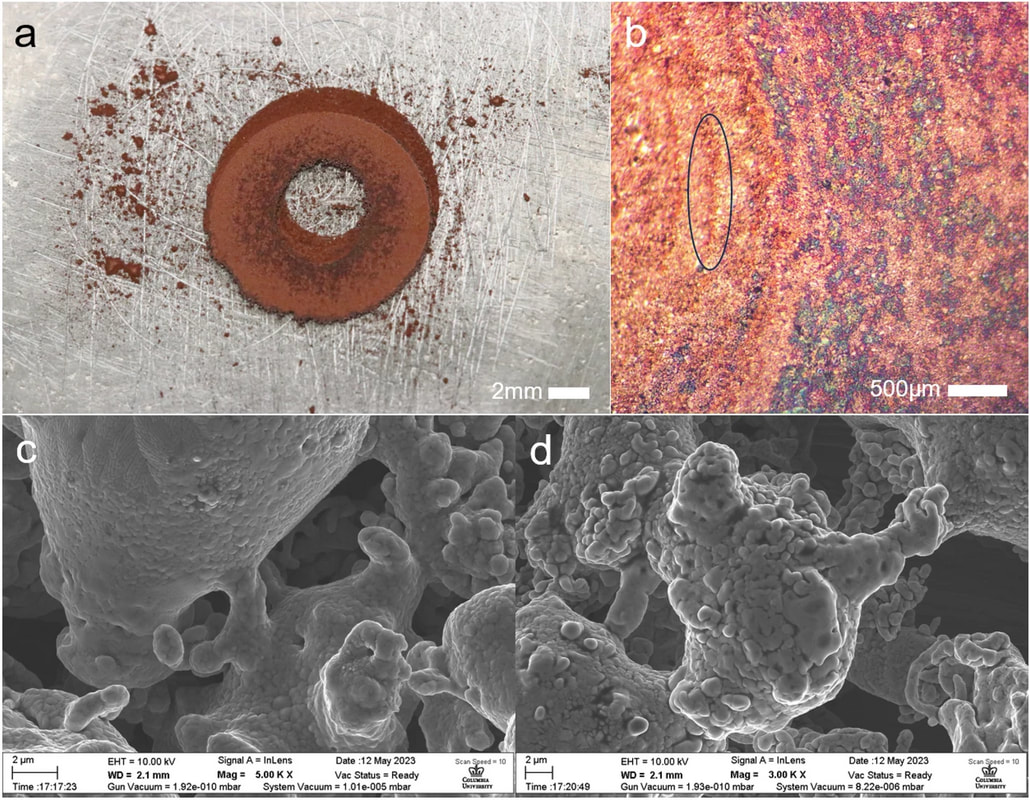
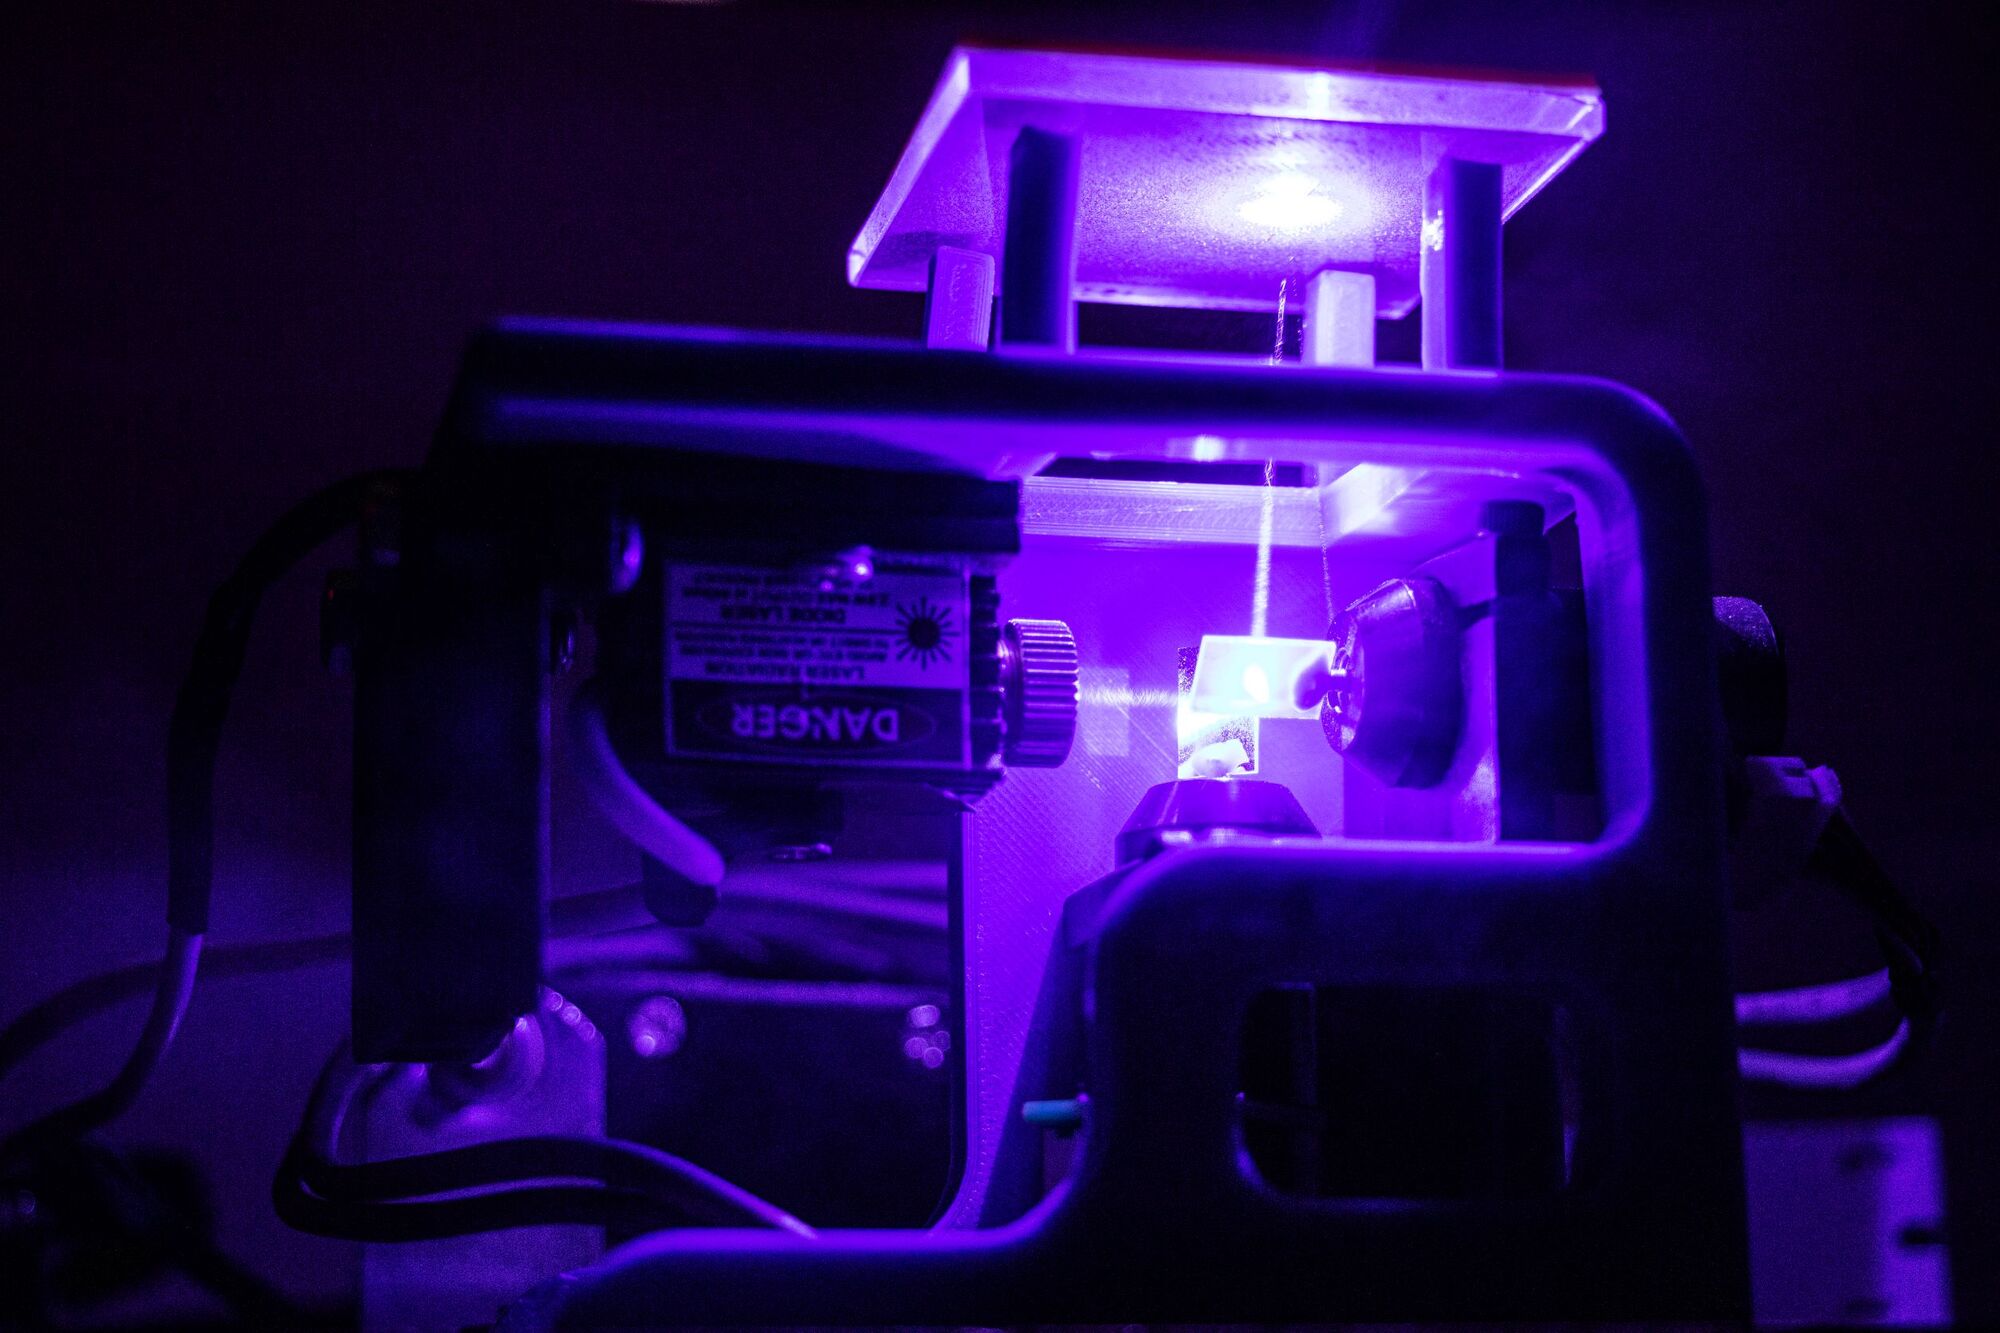
Print surface lowers onto a monolayer of powder coated on glass.
A laser is shone up through the glass, fusing powder onto the surface above.
The surface lifts with the fused layer; the glass is recoated for the next pass.
Protected under US Patent 11,648,734B2 — runner-up, Innovation of the Year, 2021.
Selected work
Across Columbia Univ., Cornell Univ., and industry, John has built smarter robots, reinvented multi-material 3D printing, and developed novel actuators, all guided by one question: What does a machine need to sense and adapt to so it can keep working?
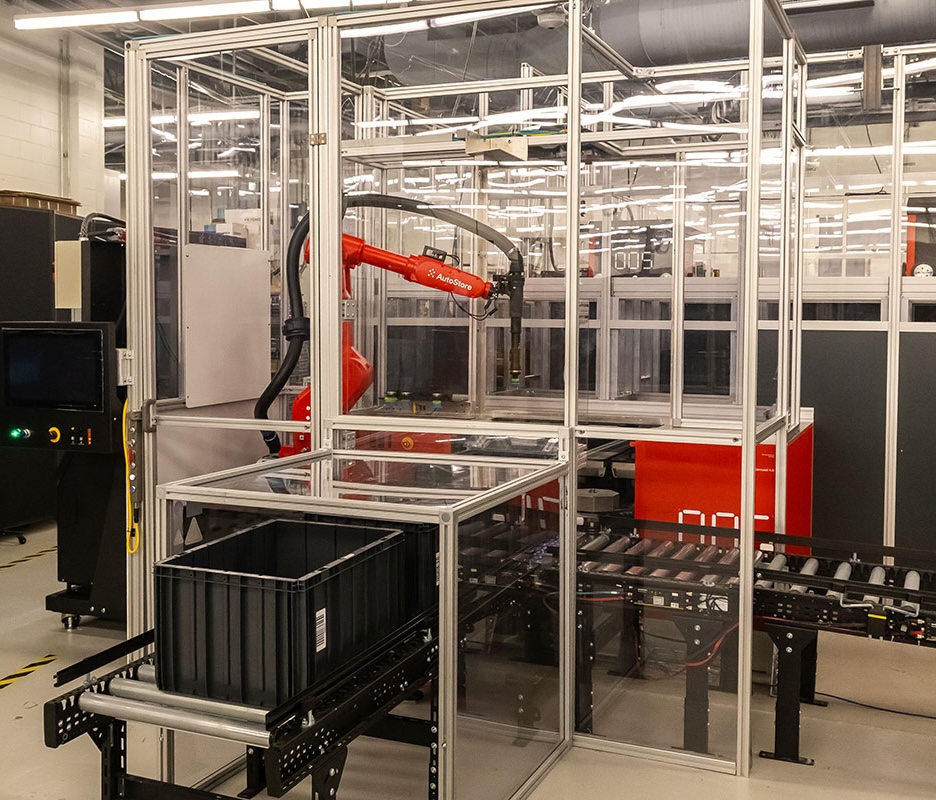
Berkshire Grey
CarouselAI
Design and deployment of an AI-powered robotic picking workstation, in active production.
Learn more →Embedded Printing
Laser Sintering
A laser-sintering process for embedding functional components directly into 3D-printed structures.
Learn more →Resilient Task
Planning
Sensor-driven control that notices when a soft robot's actuator is damaged, and steers it to be repaired.
Learn more →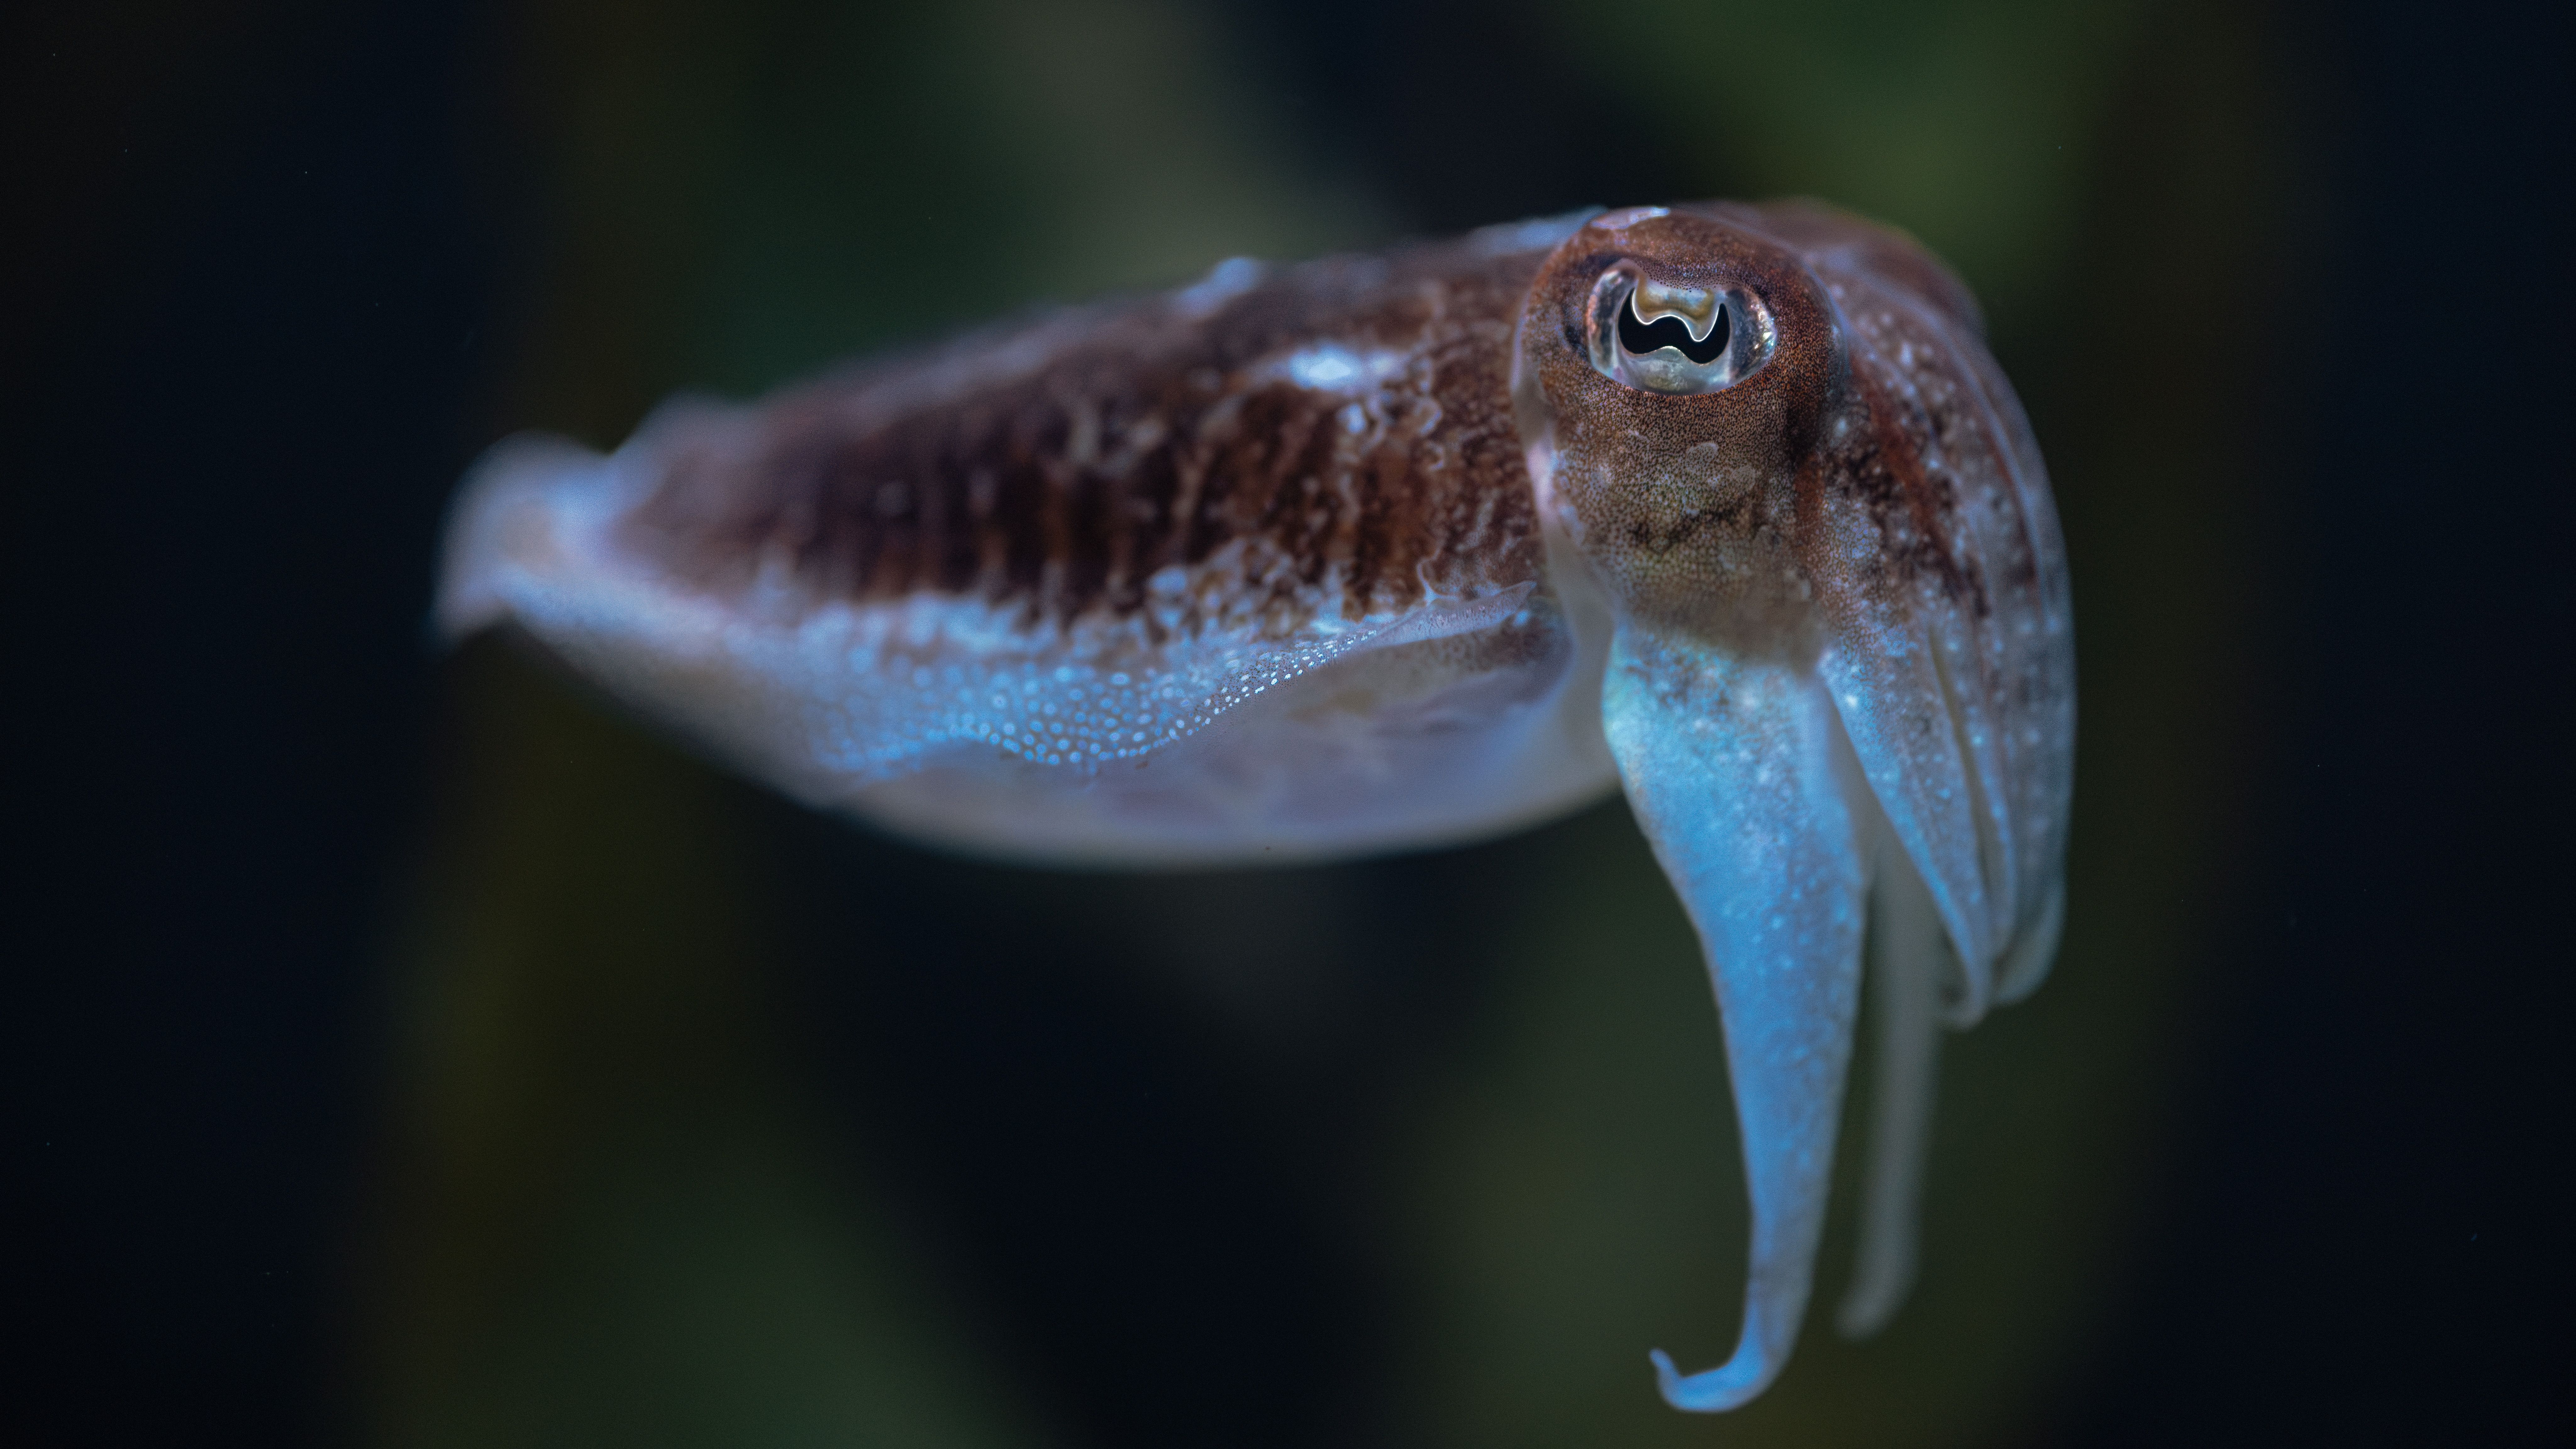
Combustion Powered
Cephalopod
A soft, tentacled robot actuated by controlled combustion rather than pneumatics.
Learn more →Sculpting Soft
Machines
Fabrication methods for compliant robot bodies built from soft, printable materials.
Learn more →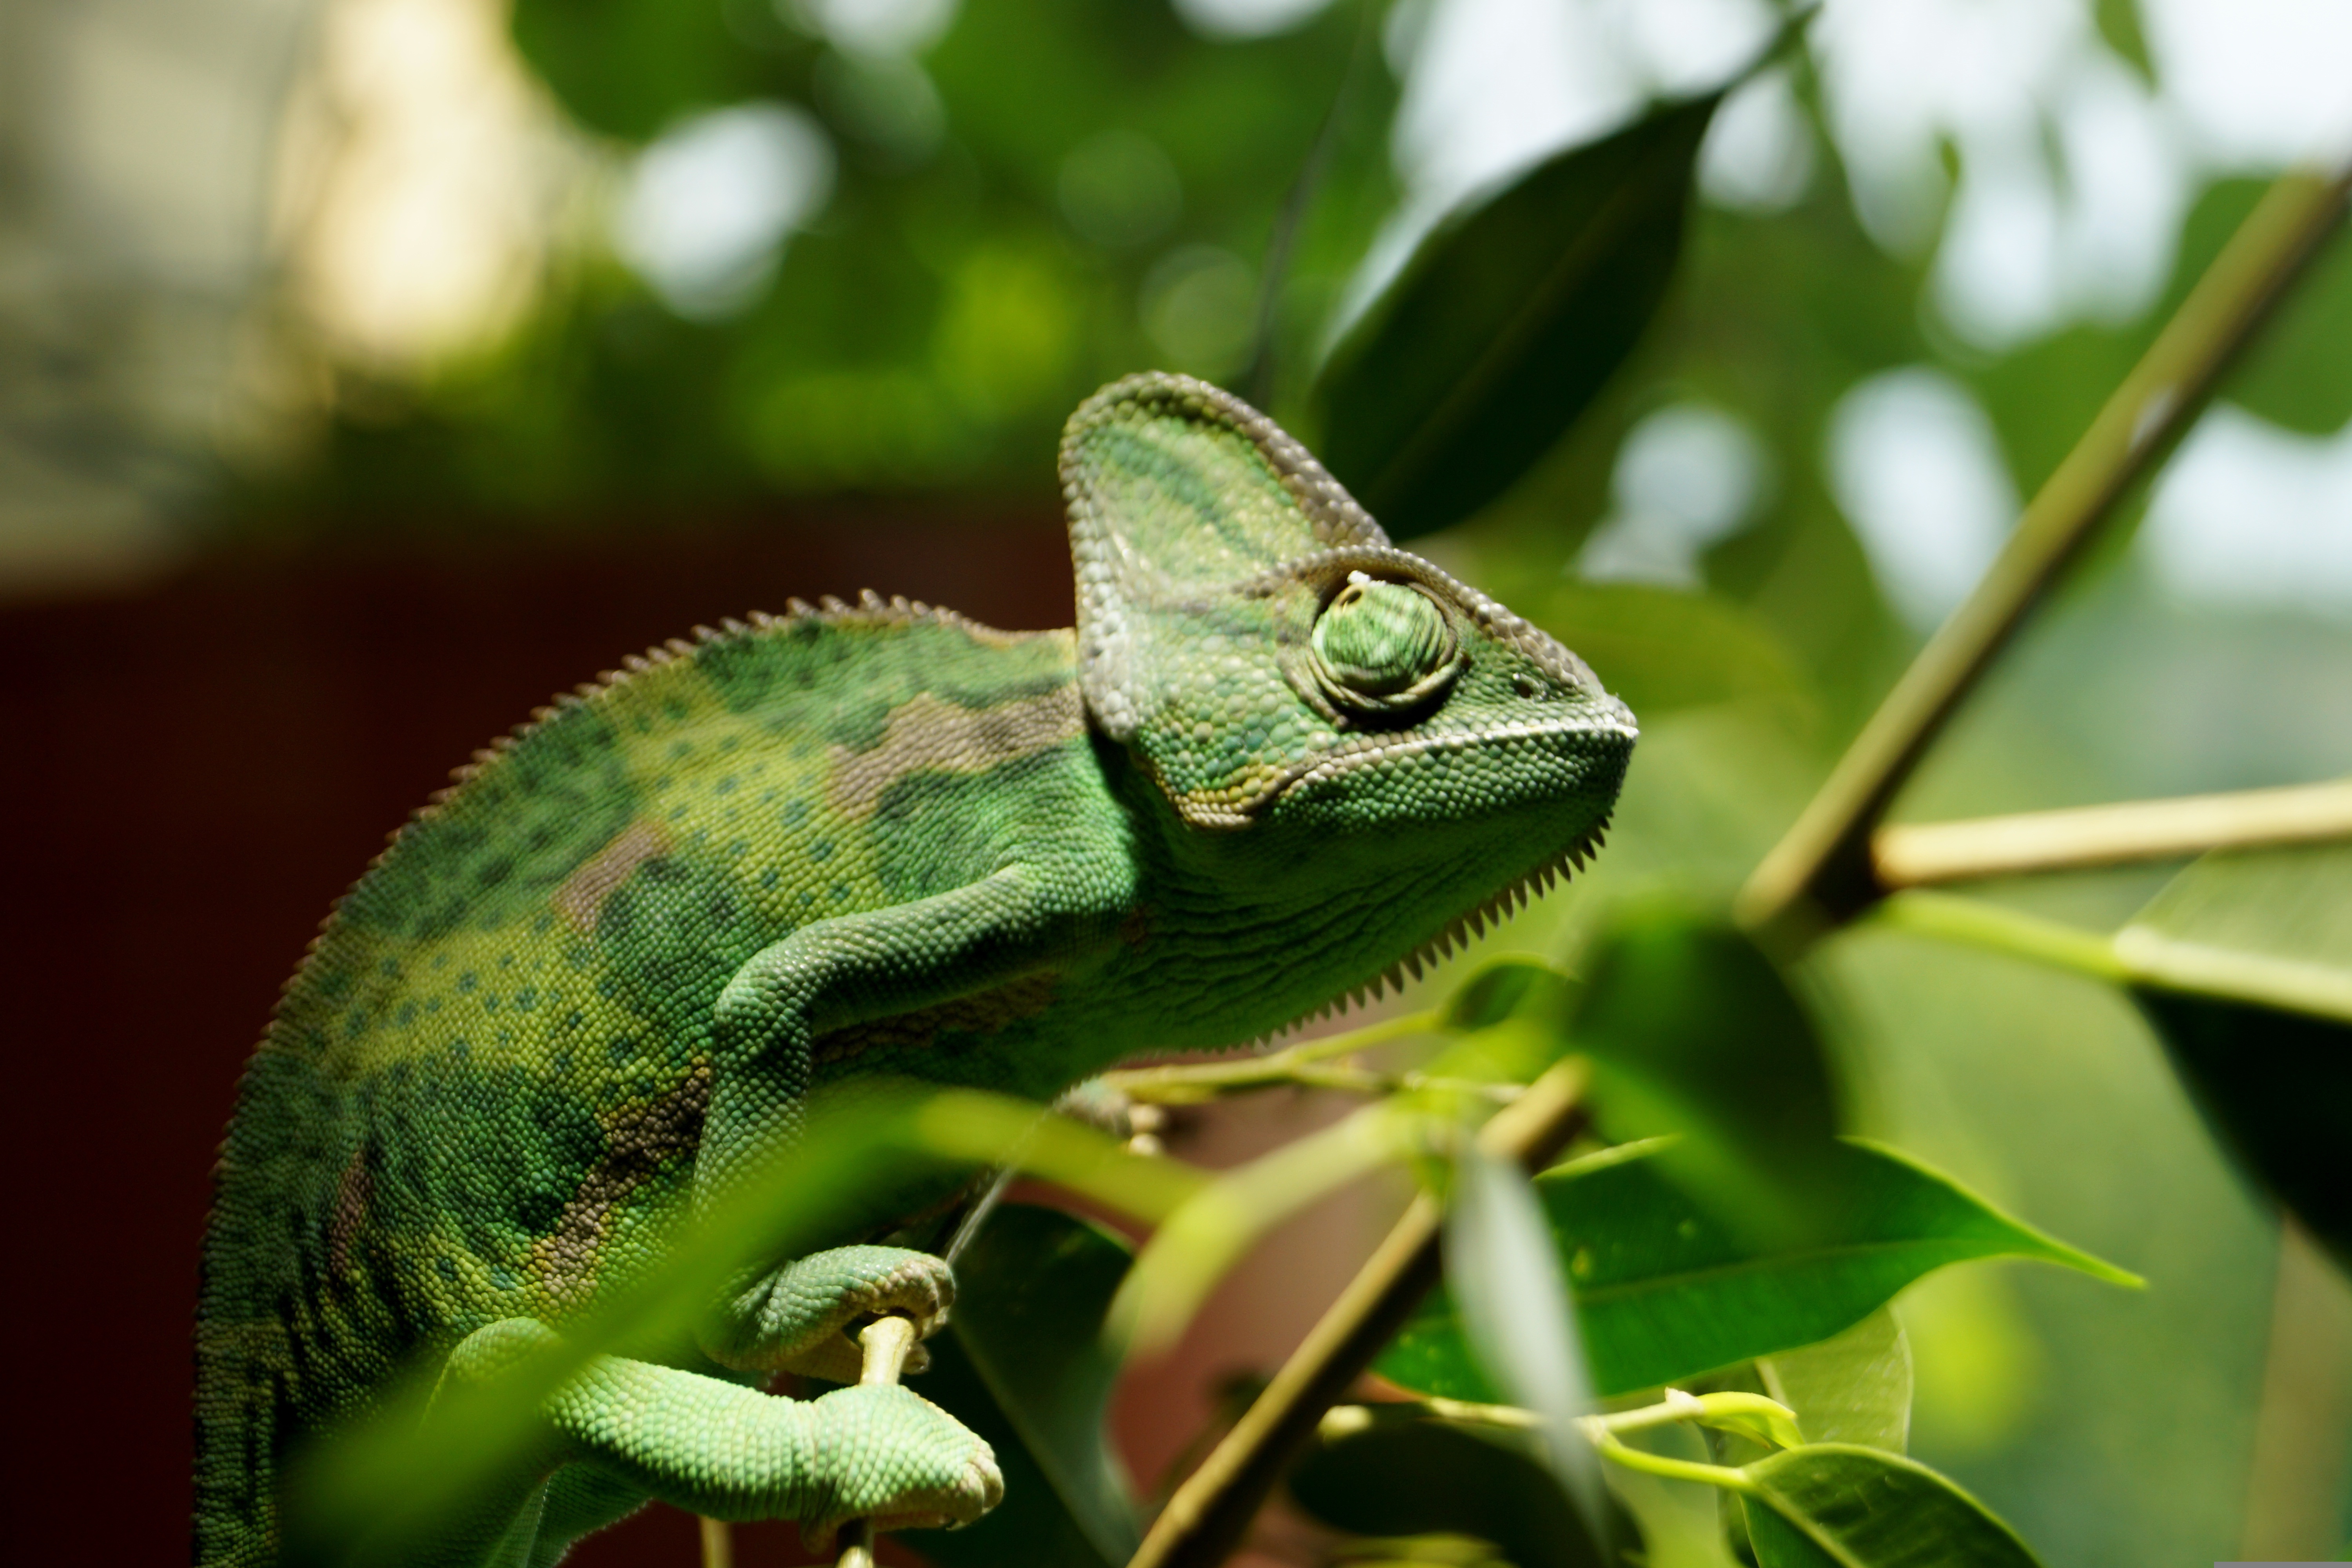
Chameleon Tongue
Actuator
A fast-extending soft actuator built on the mechanics of a chameleon's strike.
Learn more →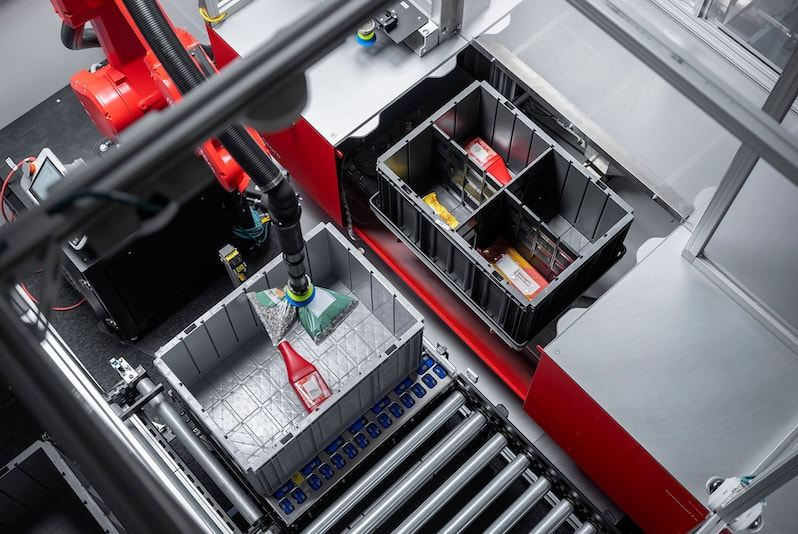
Where Lab Conditions Meet the Warehouse Floor
As Senior Mechatronics Engineer at Berkshire Grey, John worked on a variety of projects, including the design and devlopment of CarouselAI — an AI-powered automated robotic picking workstation now running in production.
During his doctoral work, he learned how to carry a complex machine from an early concept through prototyping, testing, and refinement. He now brings that experience to Berkshire Grey, helping develop commercial robotic systems that must coordinate perception, manipulation, and material flow reliably under real warehouse conditions.
Publications & recognition
 2023 — Patent
Inverted Laser Sintering Systems for Fabrication of Additively-Manufactured Parts
Read more → 2022 — Journal
Multi-Process Printing Method Combining Powder and Resin Based Additive Manufacturing
Read more → 2019 — Conference